Cómo funciona
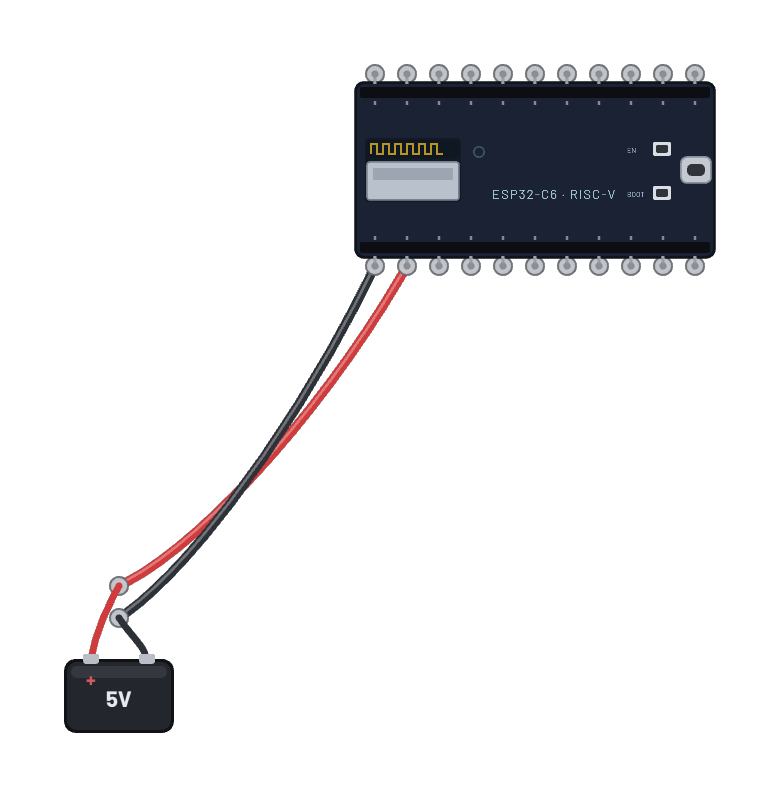
Una placa C6 cerrada ejecuta OpenThread original como firmware Arduino compilado. Al arrancar confirma un conjunto de datos completo (canal 15, PAN ID 0x1234, clave, prefijo local de malla), inicia Thread y recorre la máquina de estados real: detached y después leader de su red de un nodo, decidido por la lógica de rutas y MLE. La CLI completa OpenThread está en Serial con ot>: las mismas órdenes de un DevKit Nordic o Espressif funcionan aquí.
Componentes del montaje
- ESP32-C6
El código
Los sketches de Arduino C++ exactos con los que se compiló el firmware incluido. En el simulador, abre Code para editarlos y pulsa Compile & upload para volver a compilar el firmware de la placa.
// OpenThread leader — auto-forms a Thread network on boot, no typing needed.
//
// setup() drives the real OpenThread CLI programmatically: it commits a
// COMPLETE fixed operational dataset (timestamp, channel, PAN IDs, network
// key, PSKc, mesh-local prefix, security policy) and starts Thread. With no
// one to join, the node goes detached → leader in a few seconds. The CLI
// stays fully interactive on the serial monitor — try `state`,
// `dataset active`, `ipaddr`, `child table`.
//
// loop() pumps serial ↔ CLI itself instead of OThreadCLI.startConsole():
// the library's console worker busy-polls the stream and never lets the
// CPU idle, while this pump sleeps between polls — much friendlier to
// power (and to the emulator's idle-skip).
//
// A second board running the matching OpenThreadNode sketch (identical
// dataset, delayed start) attaches to this network as a child.

#include <Arduino.h>
#include "OThread.h"
#include "OThreadCLI.h"
#include "OThreadCLI_Util.h"

OpenThread node;

// The Breadboard Thread network — every value fixed so each boot forms the
// identical network, and any board with the same dataset can join it.
static const char *DATASET[][2] = {
  {"dataset activetimestamp", "1"},
  {"dataset channel", "15"},
  // The channel mask is a required Active-Dataset TLV — the Joiner Entrust
  // (commissioning) can't be built without it. 0x07fff800 = channels 11-26.
  {"dataset channelmask", "0x07fff800"},
  {"dataset panid", "0x1234"},
  {"dataset extpanid", "1122334455667788"},
  {"dataset networkname", "Breadboard"},
  {"dataset networkkey", "00112233445566778899aabbccddeeff"},
  {"dataset pskc", "00112233445566778899aabbccddeeff"},
  {"dataset meshlocalprefix", "fd11:2233:4455:6677::"},
  {"dataset securitypolicy", "672 onrc"},
  {"dataset commit", "active"},
  {"ifconfig", "up"},
  {"thread", "start"},
};

void setup() {
  Serial.begin(115200);
  OThread.begin(false);  // fresh start — don't resume a dataset from NVS
  OThreadCLI.begin();
  Serial.println("OpenThread starting (auto-forming): committing the Breadboard dataset.");
  for (auto &cmd : DATASET) {
    if (!otExecCommand(cmd[0], cmd[1])) {
      Serial.printf("[thread] '%s %s' failed\r\n", cmd[0], cmd[1]);
    }
  }
  Serial.println("Thread started - CLI ready, try `state`.");
  Serial.print("ot> ");
}

// Narrate role changes: disabled → detached → leader.
static void narrateRole() {
  static ot_device_role_t lastRole = OT_ROLE_DISABLED;
  ot_device_role_t role = node.otGetDeviceRole();
  if (role == lastRole) {
    return;
  }
  lastRole = role;
  Serial.printf("\r\n[thread] role: %s\r\n", node.otGetStringDeviceRole());
  if (role == OT_ROLE_LEADER) {
    Serial.printf("[thread] network \"%s\" formed: channel %u, panid 0x%04x\r\n", node.getNetworkName().c_str(), node.getChannel(), node.getPanId());
    Serial.printf("[thread] mesh-local EID: %s\r\n", node.getMeshLocalEid().toString().c_str());
    Serial.printf("[thread] rloc16: 0x%04x - waiting for children\r\n", node.getRloc16());
  }
}

// Serial ↔ CLI pump. Typed characters go to the CLI task (it executes on
// newline); responses stream back, with a fresh prompt after each command
// (the CLI ends every command with "Done" or "Error ...").
static void pumpCli() {
  while (Serial.available() > 0) {
    char ch = (char)Serial.read();
    Serial.write(ch);  // echo what you type
    OThreadCLI.write((uint8_t)ch);
  }
  static String lineBuf;
  while (OThreadCLI.available() > 0) {
    char ch = (char)OThreadCLI.read();
    Serial.write(ch);
    if (ch == '\n') {
      if (lineBuf.startsWith("Done") || lineBuf.startsWith("Error")) {
        Serial.print("ot> ");
      }
      lineBuf = "";
    } else if (ch != '\r') {
      lineBuf += ch;
    }
  }
}

void loop() {
  static uint32_t lastRoleCheck = 0;
  if (millis() - lastRoleCheck >= 250) {
    lastRoleCheck = millis();
    narrateRole();
  }
  pumpCli();
  delay(50);
}
Licencia del firmware (en inglés)
Notice: this firmware uses the LGPL-licensed Arduino core library
arduino-openthread-leader-c6.bin is statically linked with Arduino-ESP32 3.3.10. Parts of this library are licensed under the GNU Lesser General Public License, version 2.1 or (at your option) any later version. You may modify this work for your own use and reverse engineer it to debug those modifications. Download the relink package and corresponding source to rebuild it with a changed library.
- Relink package: openthread-leader-c6-relink.zip (0.9 MB)
- Required shared inputs: arduino-esp32-3.3.10-esp32c6-sdk.zip (10.0 MB), arduino-esp32-3.3.10-notices.zip (0.1 MB)
- Corresponding source: arduino-esp32-3.3.10-core-source.zip (1.2 MB), arduino-esp32-3.3.10-esp32c6-headers-source.zip (2.1 MB)
- Licence texts and relink instructions
Prueba esto
- Escribe state en ot>: leader cuando se estabiliza la formación.
- Escribe dataset active para leer los parámetros confirmados.
- Escribe ipaddr para ver las direcciones locales de malla y enlace derivadas por Thread.
- Selecciona 802.15.4 del C6: PAN ID 0x1234 en vivo al formarse la red.